
DOC 03SIMULATION CONTENT
Vehicles
LEVIATHAN has nine built-in vehicles: three remotely operated vehicles, four autonomous underwater vehicles, an autonomous surface vessel and a buoyancy-driven glider. You choose them from Vehicle in the Viewport, and you can import your own.
Vehicle names identify the class of vehicle a preset represents. Their physical parameters are LEVIATHAN simulation presets, most of them approximate, and are not manufacturer data. Where a parameter comes from a published source, it is marked below. Naming a vehicle implies no affiliation with its manufacturer.
Catalogue
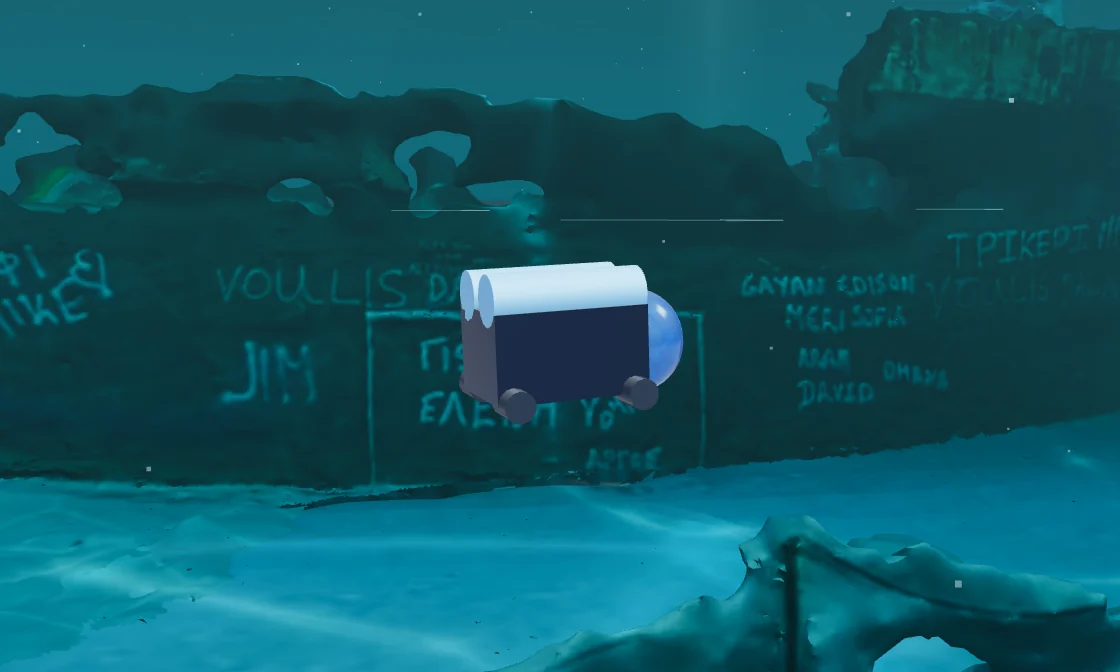
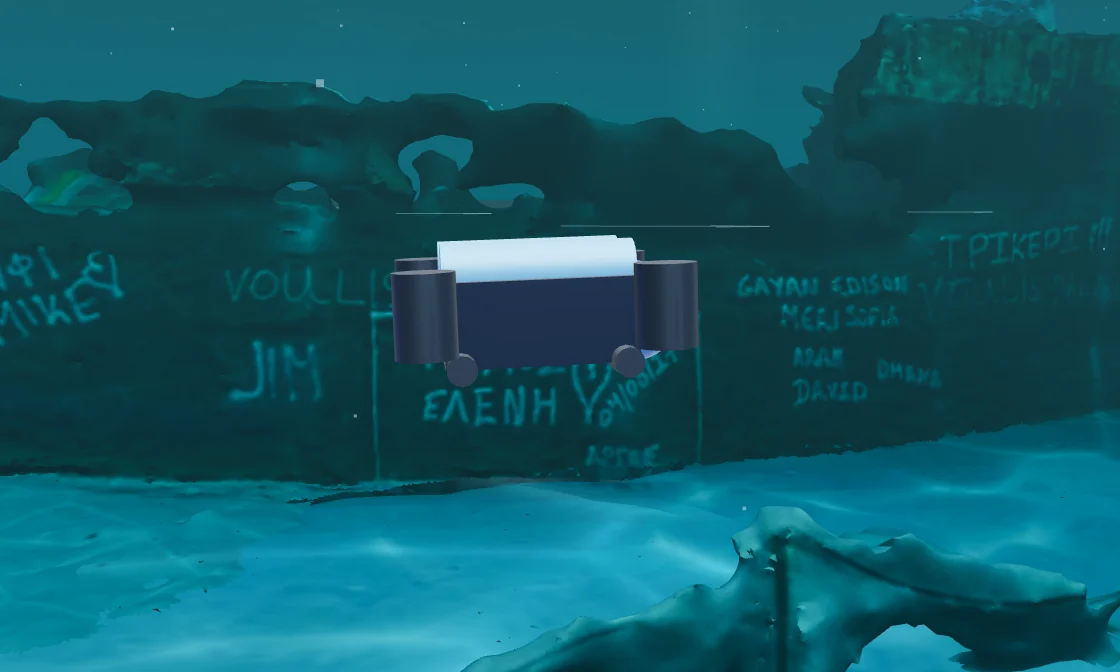
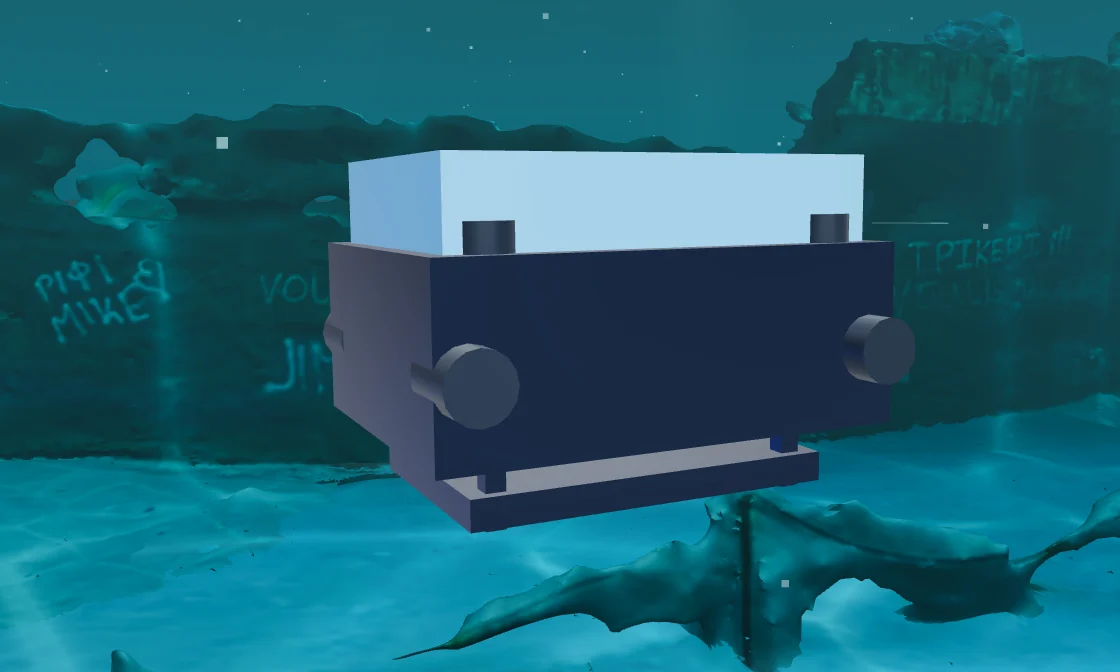
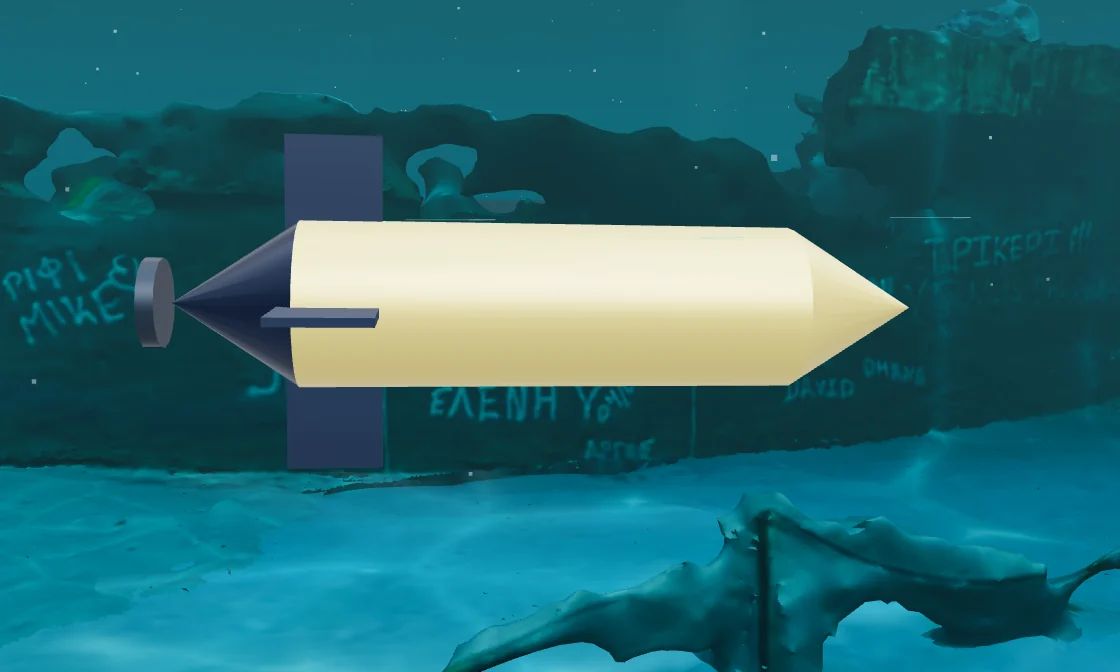
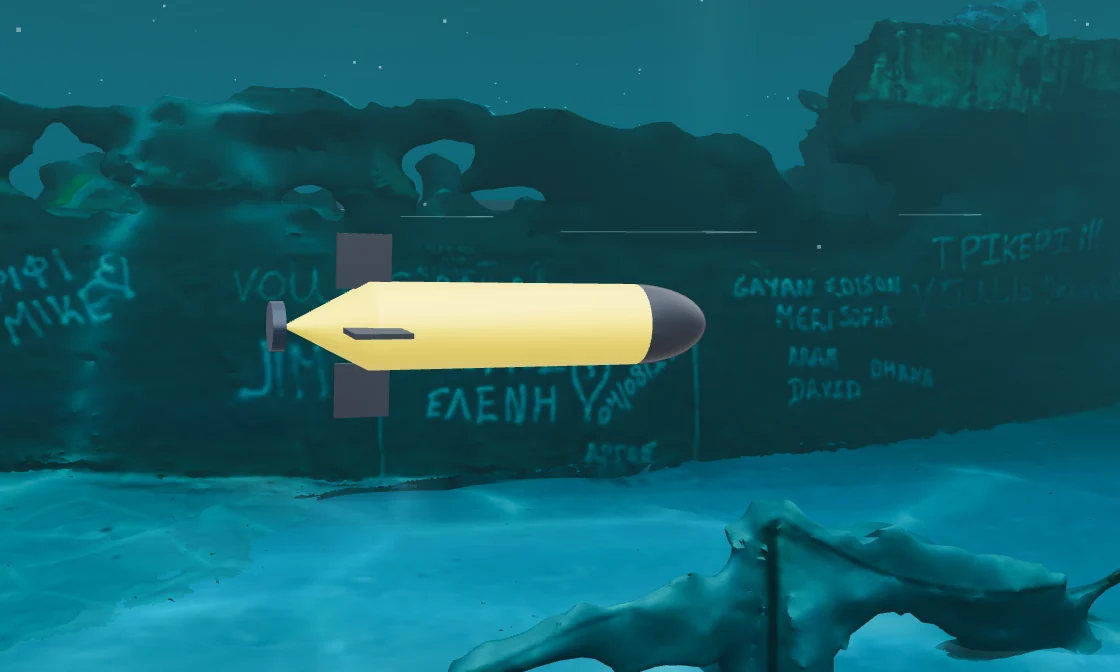
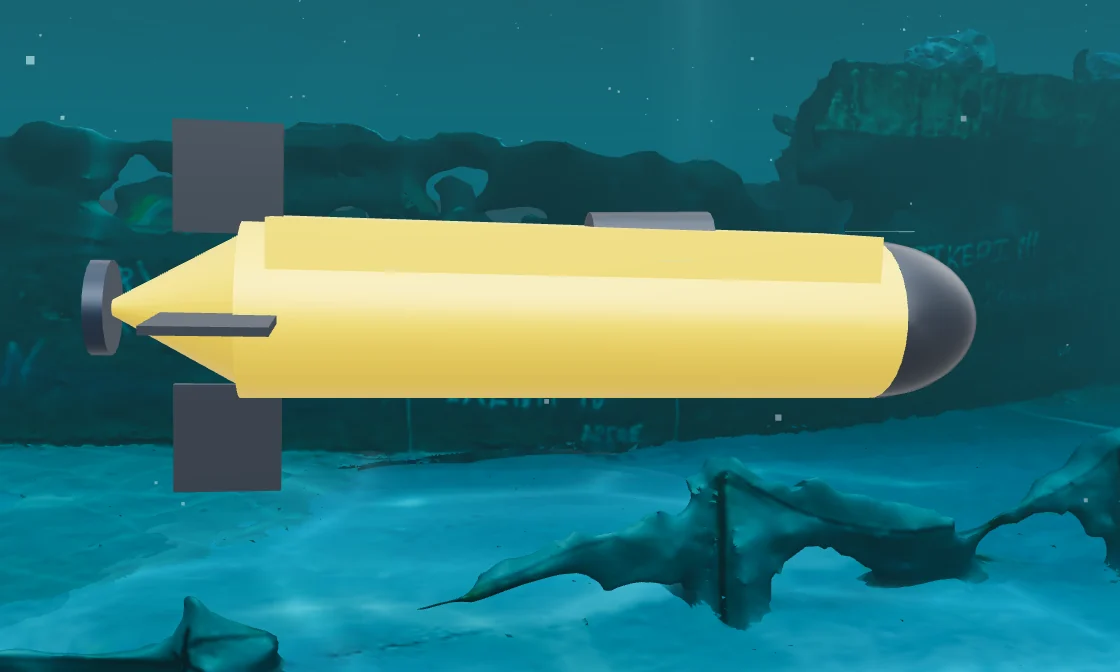
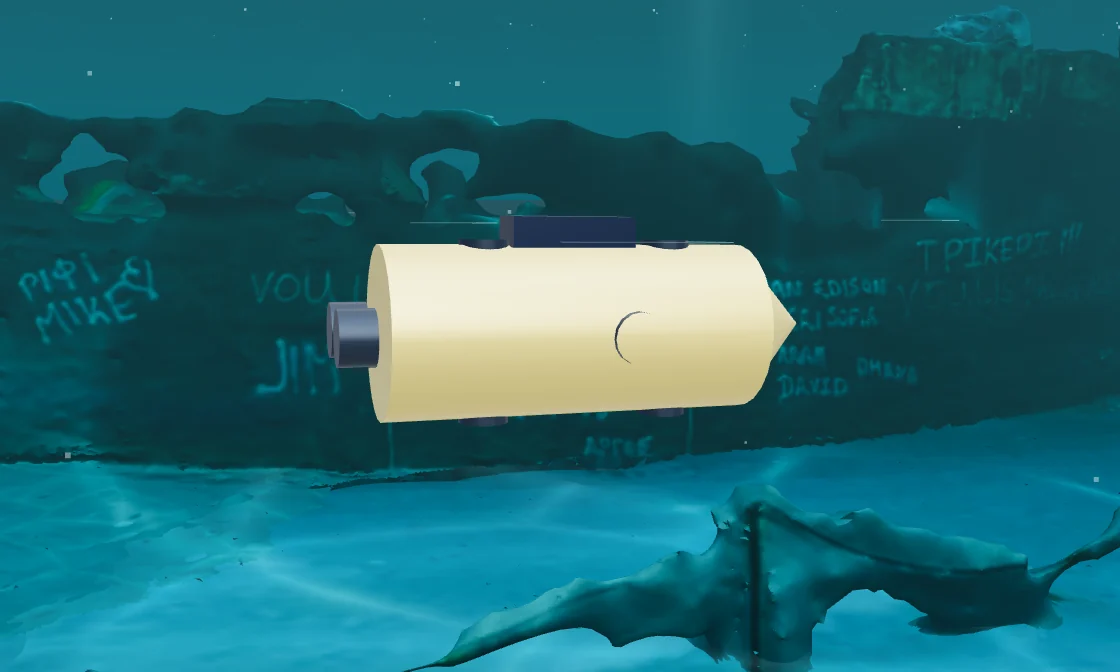
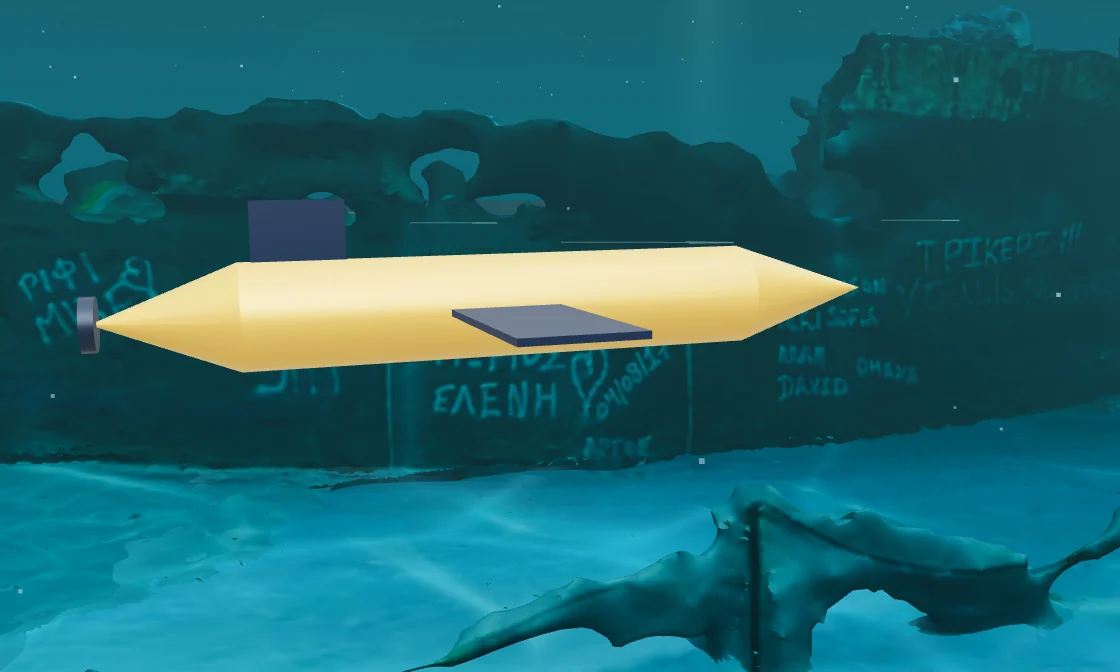
Each vehicle is shown side-on at the Shipwreck at the same camera distance. Viewport models are simplified representations for visualisation. The USV is not pictured: it rides the surface, above the Viewport's default underwater camera.
| Vehicle | Class | Actuation | Mass | Displacement | Hull |
|---|---|---|---|---|---|
| BlueROV2 | ROV | Viewport model; no physics preset is linked to it | — | — | — |
| BlueROV2 Heavy | ROV | 8 thrusters: 4 vectored horizontal, 4 vertical | 11.5 kg | 0.0112 m³ | — |
| BlueROV2 Heavy (faithful) | ROV | Same layout as the Heavy | 13.5 kg | 0.0132 m³ | — |
| Work-class ROV | ROV | 8 thrusters, 120 N each; 0.3 s spin-up, 1.5 N dead-band | 75 kg | 0.0732 m³ | — |
| Torpedo AUV | AUV | 1 stern thruster; rudder and elevator | 18 kg | 0.0176 m³ | 1.3 × 0.16 m |
| REMUS-100 | Survey AUV | 1 stern propeller, 80 N; rudder and elevator | 31.0 kg | 0.0302 m³ | 1.6 × 0.19 m |
| HUGIN Survey | Survey AUV | 1 stern propeller, 1500 N; rudder and elevator | 1811 kg | 1.767 m³ | 6.0 × 0.75 m |
| Hovering AUV | AUV | 5 thrusters, 60 N each: 2 stern, 1 lateral, 2 vertical | 55 kg | 0.0537 m³ | — |
| USV (ASV) | Surface vessel | 2 transom thrusters, 80 N each; under-actuated in sway | 150 kg | 0.146 m³ | — |
| Underwater glider | Glider | Buoyancy engine ±4 N and fixed wings; small 8 N auxiliary thruster | 52 kg | 0.0507 m³ | — |
"BlueROV2 Heavy (faithful)" appears in the Dashboard's vehicle lists rather than in the Viewport menu. The glider is driven by its buoyancy engine and wings through a sawtooth dive-and-climb profile (Simulate → Glide). It is not part of the learning task suite, which uses thruster-driven vehicles.
Hydrodynamic coefficients
| Preset | Inertia Ixx, Iyy, Izz | Added mass | Linear damping | Quadratic damping |
|---|---|---|---|---|
| BlueROV2 Heavy | 0.16, 0.16, 0.16 | 5.5, 12.7, 14.6, 0.12, 0.12, 0.12 | 4.03, 6.22, 5.18, 0.07, 0.07, 0.07 | 18.2, 21.7, 37.0, 1.55, 1.55, 1.55 |
| BlueROV2 Heavy (faithful) | 0.26, 0.23, 0.37 | 6.36, 7.12, 18.7, 0.186, 0.135, 0.40 | 13.7, 0, 33.0, 0, 0.8, 0 | 141, 217, 190, 1.55, 1.55, 1.55 |
| Work-class ROV | 4.2, 4.6, 6.0 | 38, 70, 90, 2.4, 2.6, 3.2 | 26, 40, 48, 3.5, 3.8, 4.5 | 120, 160, 220, 22, 24, 30 |
| Torpedo AUV | 0.08, 2.5, 2.5 | 2, 18, 18, 0.05, 4, 4 | 3, 25, 25, 0.1, 8, 8 | 6, 120, 120, 1, 40, 40 |
| REMUS-100 | 0.11, 4.02, 4.02 | 0.84, 29.4, 29.4, 0.078, 2.82, 2.82 | 0, 0, 0, 0, 0, 0 | 14.5, 122, 122, 0.039, 7.35, 7.35 |
| HUGIN Survey | 102, 3311, 3311 | 53, 1711, 1711, 71, 2318, 2318 | 0, 0, 0, 0, 0, 0 | 226, 1811, 1811, 9.6, 1547, 1547 |
| Hovering AUV | 0.9, 7.0, 7.0 | 8, 45, 45, 0.2, 9, 9 | 12, 60, 60, 0.4, 14, 14 | 20, 220, 220, 2, 70, 70 |
| USV (ASV) | 22, 60, 70 | 20, 90, 110, 6, 35, 30 | 20, 80, 30, 8, 30, 18 | 28, 220, 90, 30, 120, 70 |
| Underwater glider | 0.7, 14, 14 | — | 4, 50, 18, 0.3, 9, 8 | — |
REMUS-100, HUGIN Survey and the torpedo AUV also use cross-flow drag along their slender hulls (coefficient 1.1). For these presets the strip integral supplies the sway, heave, pitch and yaw drag. The USV has a waterplane area of 1.1 m², transverse and longitudinal metacentric heights of 0.45 m and 1.8 m, and frontal and lateral wind areas of 0.42 m² and 0.95 m². Each fin-steered vehicle has a rudder and an elevator: 0.0095 m² each on the torpedo AUV, 0.014 m² on REMUS-100 and 0.18 m² on HUGIN.
Provenance
| Preset | Source and status |
|---|---|
| BlueROV2 Heavy | Approximate, chosen for a gentle, passively stable vehicle under simple controllers. It uses the standard BlueROV2's mass and isotropic inertia, and its quadratic damping is well below pool-measured values. Its full-thrust surge speed is therefore about 2 m/s, where the published measurement is about 0.72 m/s. |
| BlueROV2 Heavy (faithful) | Published mass, anisotropic inertia, added mass and a 1 cm centre-of-buoyancy offset for the BlueROV2 Heavy. Linear and translational quadratic damping come from von Benzon et al. (2022, J. Mar. Sci. Eng. 10(12):1898, Table A1), measured in a 6.1 m pool. With them a full-thrust surge settles near 0.73 m/s, against 0.72 m/s measured. Rotational quadratic damping is not from that source. The stronger added-mass asymmetry needs an attitude loop: use station keeping with levelling and a step of 0.05 s or less. |
| Work-class ROV | Approximate, scaled up from the Heavy with size. |
| Torpedo AUV | Approximate. It steers only with its fins, so it can manoeuvre under way but cannot hold station. |
| REMUS-100 | A REMUS-100-class geometry (1.6 × 0.19 m). Hull hydrodynamics are an ellipsoid estimate, with Lamb added mass and form drag from the bounding box. Not REMUS data. The fin stall angle is flagged as unsourced. |
| HUGIN Survey | A representative large survey AUV (6 × 0.75 m). Its mass is that of a neutrally buoyant solid hull of that size; a real free-flooded vehicle is lighter in air. |
| Hovering AUV, USV, glider | Approximate parameters for the vehicle class, to be refined by system identification. |
Before a run, a vehicle can be checked for physical coherence. Negative added mass, non-positive inertia or negative damping make the check fail. A hull that would sink or capsize produces a warning instead, because heavy landers and unstable hulls are legitimate test cases.
Body frame and sensor mounts
Every vehicle's body frame is FRD: x forward, y starboard, z down, with its origin at the centre of gravity (see Coordinate frames). In the canonical vehicle catalogue, each vehicle is a document of links and sensors. Every sensor declares a type, the link it is attached to, a mount transform and the frame convention of its type: OpenCV optical for cameras, sensor FRD for acoustic and inertial sensors. Mounts also record their source. The built-in camera mounts sit at the front of each hull, with the optical axis along body x; they are not measured from manufacturer CAD.
| Vehicle | Front camera |
|---|---|
| BlueROV2 | 0.62 m |
| BlueROV2 Heavy | 0.78 m |
| Work-class ROV | 1.05 m |
| Torpedo AUV | 1.42 m |
| REMUS-100 | none declared |
| HUGIN Survey | none declared |
| Hovering AUV | 0.95 m |
| USV (ASV) | 1.2 m |
| Underwater glider | 1.3 m |
Reference vehicles
Besides the nine built-in vehicles, the canonical catalogue holds reference vehicles that are explicitly labelled as test and reference models, not production vehicles. They borrow the BlueROV2 Heavy physics preset and declare richer sensor sets, with declared test rates rather than device specifications. Two of them carry the navigation sensors the localization estimator uses.
| Reference vehicle | Declared sensors |
|---|---|
| Reference ROV | Camera, imaging sonar, IMU |
| Reference survey ROV | Camera, imaging sonar, DVL, IMU |
| Reference navigation ROV | Camera, imaging sonar, DVL, IMU, magnetometer, pressure |
| Reference navigation ROV with USBL | As above, plus a USBL transponder |
Representing your platform
LEVIATHAN describes every vehicle the same way: a rigid body with mass, inertia, added mass and damping, plus thrusters, fins or wings, and sensors on declared mounts. The built-in presets cover the common classes. Your own robot fits the same model.
| Platform | How to represent it |
|---|---|
| Open-frame ROV | Start from the BlueROV2 Heavy or Work-class ROV presets, or import a URDF, SDFormat or MJCF description with its thruster layout |
| Torpedo or survey AUV | Torpedo AUV, REMUS-100 or HUGIN presets, with fins for steering and cross-flow drag; hydrodynamics can come from hull dimensions |
| Hovering AUV | The Hovering AUV preset, with lateral and vertical thrusters |
| Surface vessel | The USV preset, with a waterplane area, metacentric heights and wind areas |
| Glider | The glider preset, driven by its buoyancy engine and wings |
| Custom hull | Upload a CAD mesh; volume, centre of buoyancy and projected areas come from the geometry, with uncertainty bounds |
| Hull-crawling robot | Modelled in the Hull workspace, with magnetic adhesion, lanes on the hull and cleaning. It is not a free-swimming vehicle preset |
Canonical sensors are declared in a vehicle's catalogue model, with their mount transforms and sampling schedules: camera, sonar, DVL, IMU, pressure sensor, magnetometer and USBL. The canonical catalogue ships with LEVIATHAN and consists of the built-in and reference vehicles; imported and uploaded vehicles get physics, and the analytic sensors in the Viewport, but no canonical catalogue entry.
Custom vehicles
Import URDF, SDFormat or MJCF
Choose Vehicle → Import URDF / SDF / MJCF… and select a robot description. LEVIATHAN reads link geometry and inertial mass, fits a bounding hull, and estimates the hydrodynamic coefficients from it. Translational added mass comes from potential flow about the equivalent ellipsoid (Lamb), quadratic drag from the projected areas, and rotational terms and linear damping from heuristics you can tune. The vehicle is neutrally buoyant unless you give a density or mass. It is then registered and checked, and it appears in the vehicle lists.
Import takes link geometry and inertial mass only. Joints, transmissions, simulator plugins, include files and external mesh references are not resolved. When an SDFormat world contains several models, the first is bound and the others are reported.
Upload a CAD hull
Vehicle → Upload CAD… accepts glTF/GLB, OBJ, STL and COLLADA meshes. The mesh becomes a registered vehicle with physics derived from its geometry: volume, centre of buoyancy and projected areas are computed from the mesh. Each result comes with uncertainty bounds, which can seed domain randomisation. Registered hulls are kept in a local vehicle store as derived parameters with a content hash of the source geometry. They survive restarts and can be selected wherever a preset can, including the learning tasks. You can add thruster positions and directions, a mass or density, and a per-thruster force limit.
The FAB Engine also has a mesh-based hydrodynamics tier that integrates hydrostatic and hydrodynamic forces face by face over a closed mesh. It handles partial submergence and spatially varying flow, at roughly a hundred times the cost of the coefficient model per step. It is used where a body's geometry matters more than throughput, for example when binding bodies from Stonefish scenario files.